Home / Goods-to-person picking
Vision-guided picking. At the shelf or in the cell.
A collaborative arm with a vacuum gripper picks totes and items. On Picker P1 it rides a mobile base with a lift mast to the shelf; in the fixed cell, stock totes come to it from storage and cameras find each item. People stay outside the robot's working area.
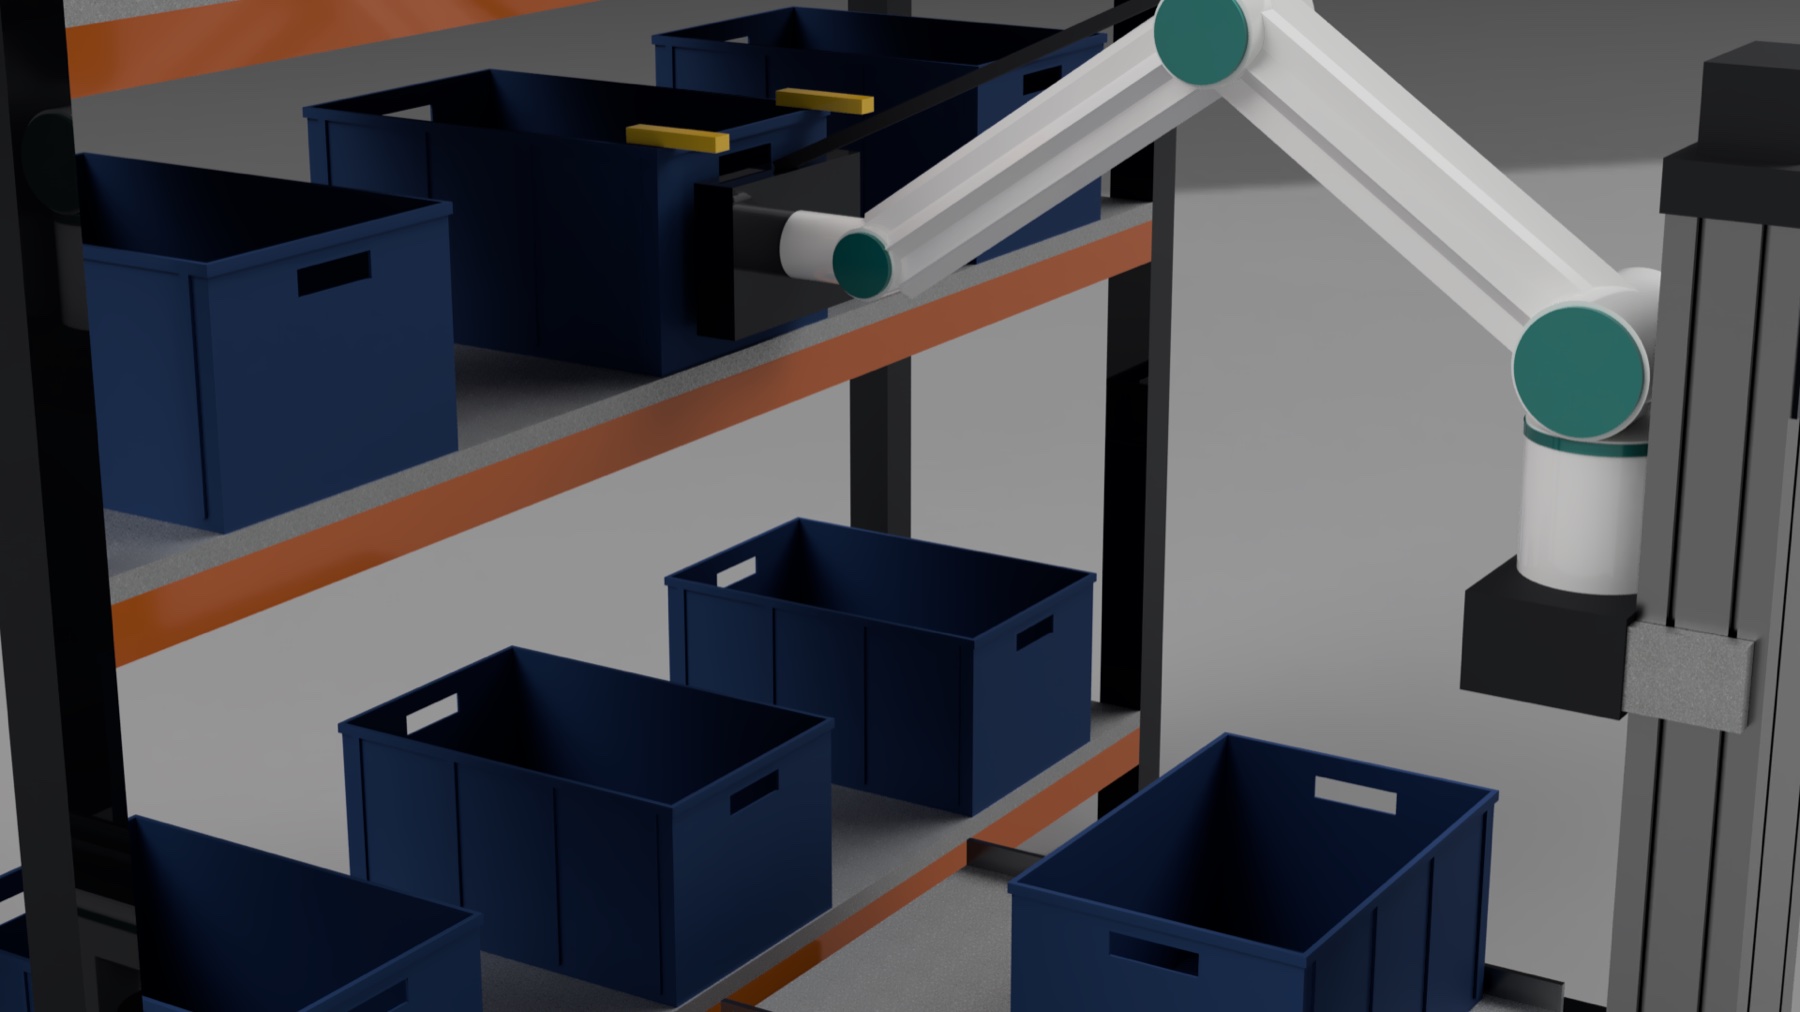
See it. Pick it. Place it.
The cameras scan the stock tote, mark the item and guide the arm.
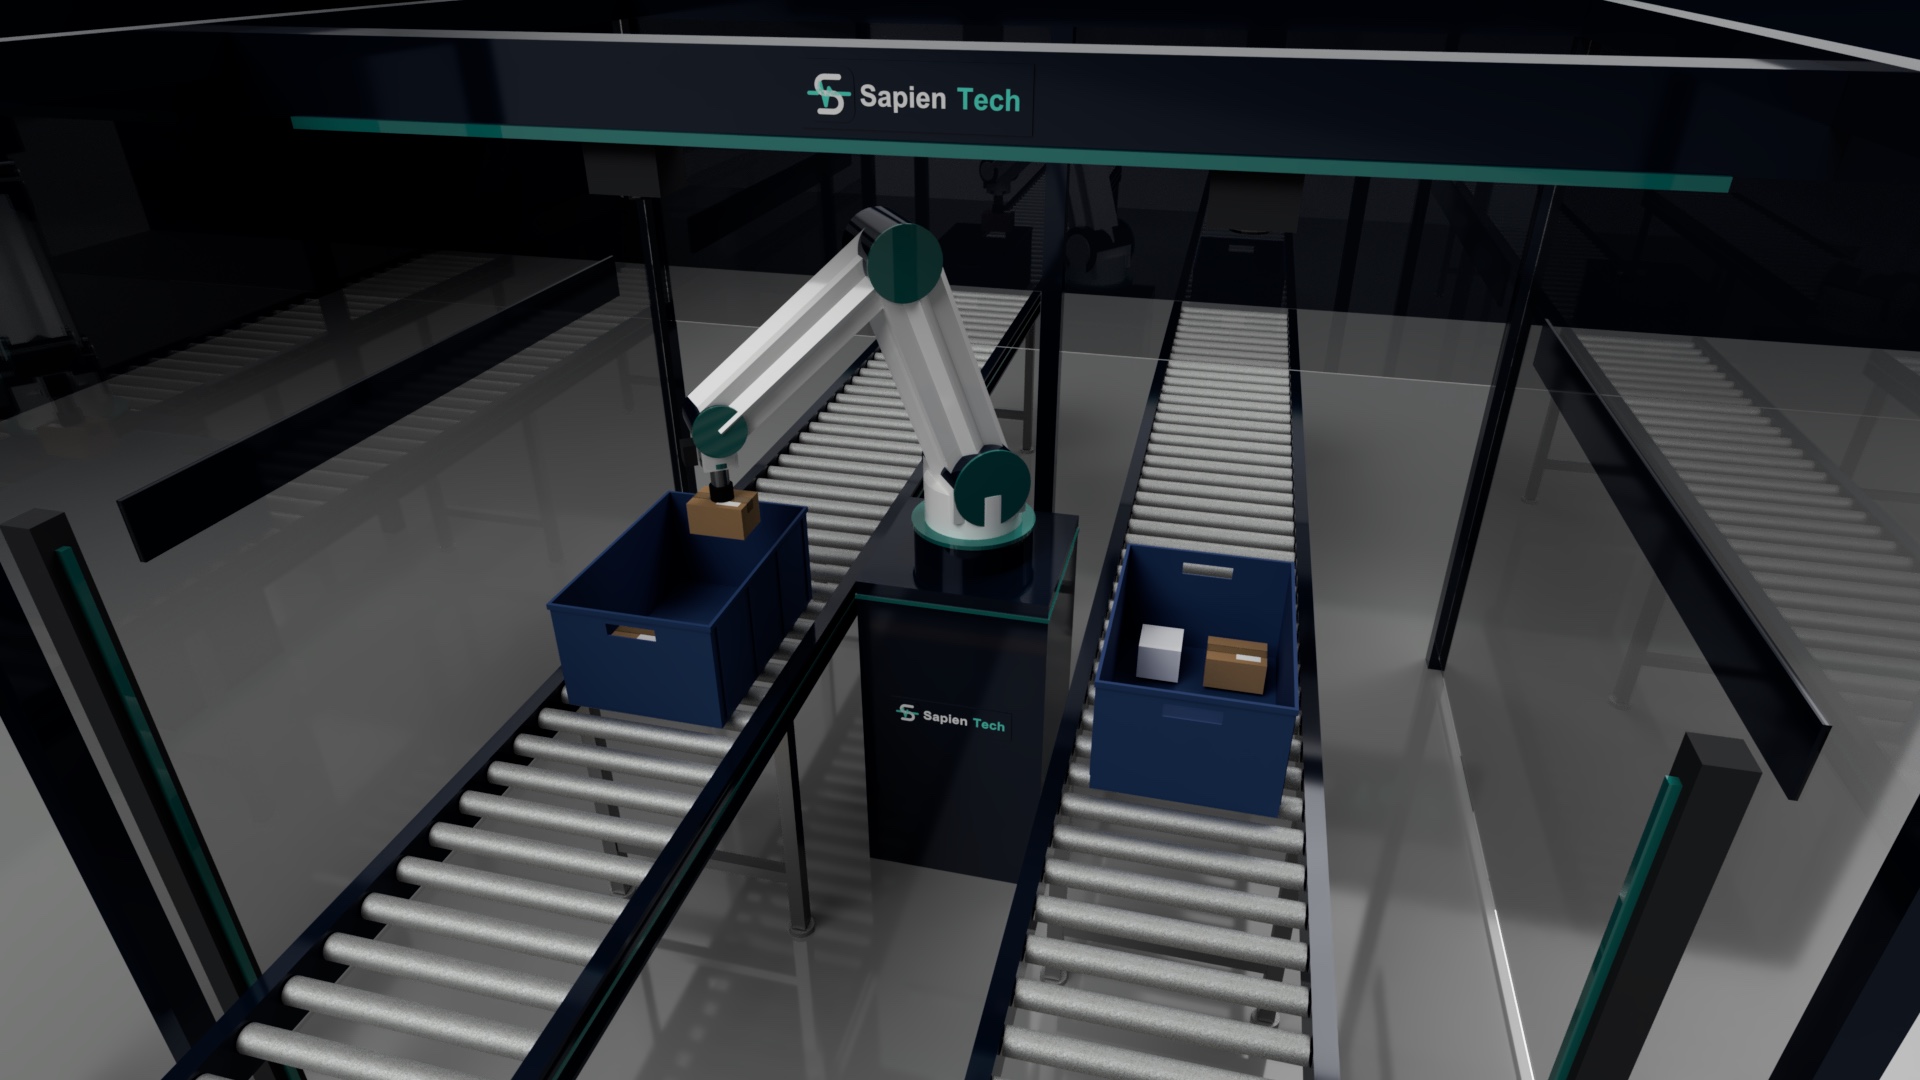
- Vision. Overhead cameras find each item and its best pick point.
- Suction gripper. The arm lifts boxes, bottles and packs.
- Two ports. Stock tote in on one side, order tote on the other.
- Guarded. Perimeter guarding and protective devices are proposed. Access, openings, stopping performance and restart conditions require risk assessment and validation.
Start with your items.
We size the cell around your items and orders.
Item range
Sizes, weights, shapes and packaging.
Order profile
Lines per order and peak picks per hour.
Integration
Links to storage, conveyors and your warehouse system.
Picking questions.
Can I order this now?
Not yet. The cell is in development. We can plan it with you now.
Which items can it pick?
Most boxed and bottled goods. Soft or odd items need testing first.
Does it connect to storage?
Yes. It is built to sit at the port of our tote storage, or your own.
The numbers in one place.
Design and target values for this machine. None are tested yet unless marked Market. On a phone, swipe the table sideways.
| Item | Value | Type |
|---|---|---|
| Cell | One robot arm with a suction gripper | Design |
| Vision | Overhead cameras find each item and its pick point | Design |
| Ports | 2: stock tote in on one side, order tote on the other | Design |
| Tote size | 600 × 400 × 280 mm, the same as tote storage | Design |
| Items | Boxed and bottled goods; soft or odd items need testing first | Design |
| Guarding | Glass panels and a light curtain | Design |
| Pick rate | Not claimed yet | To be measured |
Tote to tote, in the engineering model.
The arm picks from a source tote on one conveyor and places into an order tote on the next, rendered from the Fusion design model.
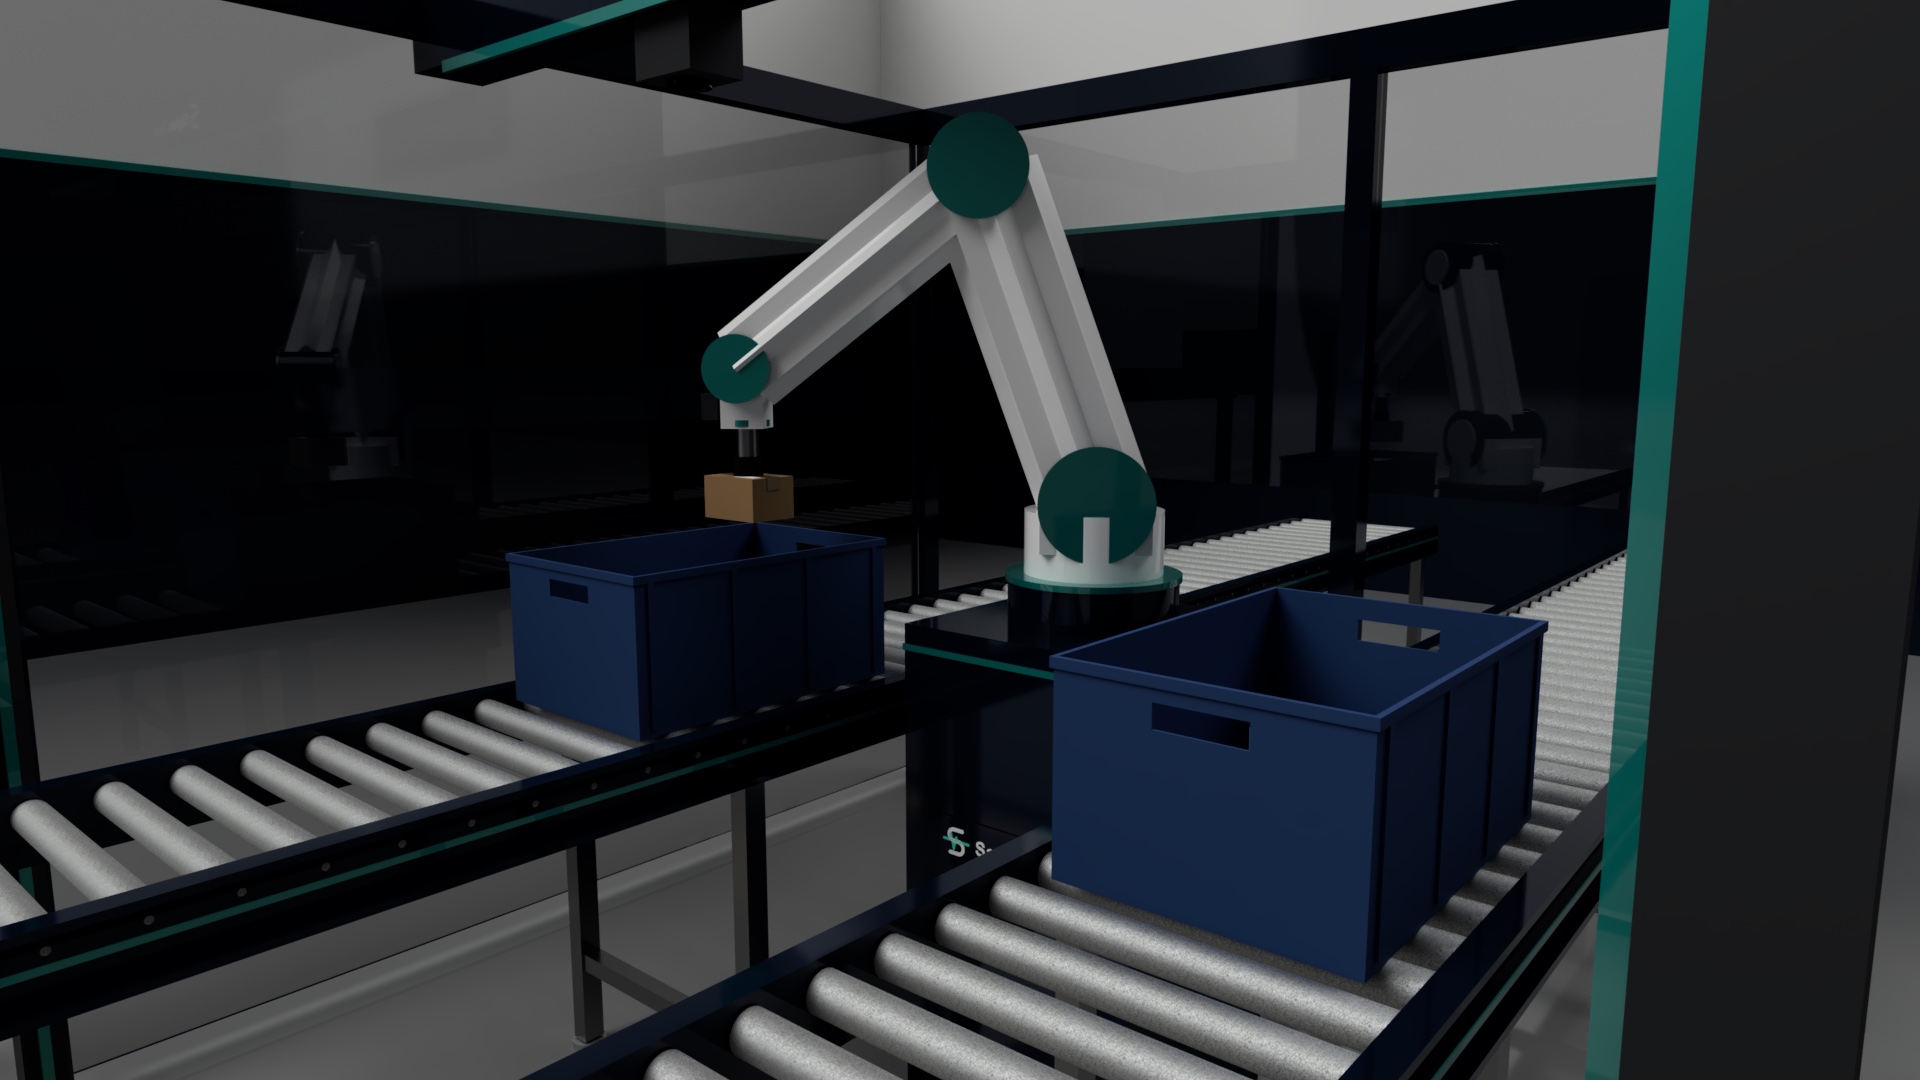
Concept · 3D design No physical testing yet; ratings are published only after testing.
The same arm, on wheels.
Picker P1 carries the arm and gripper to the shelf on a mobile base with a lift mast, for sites without tote storage.
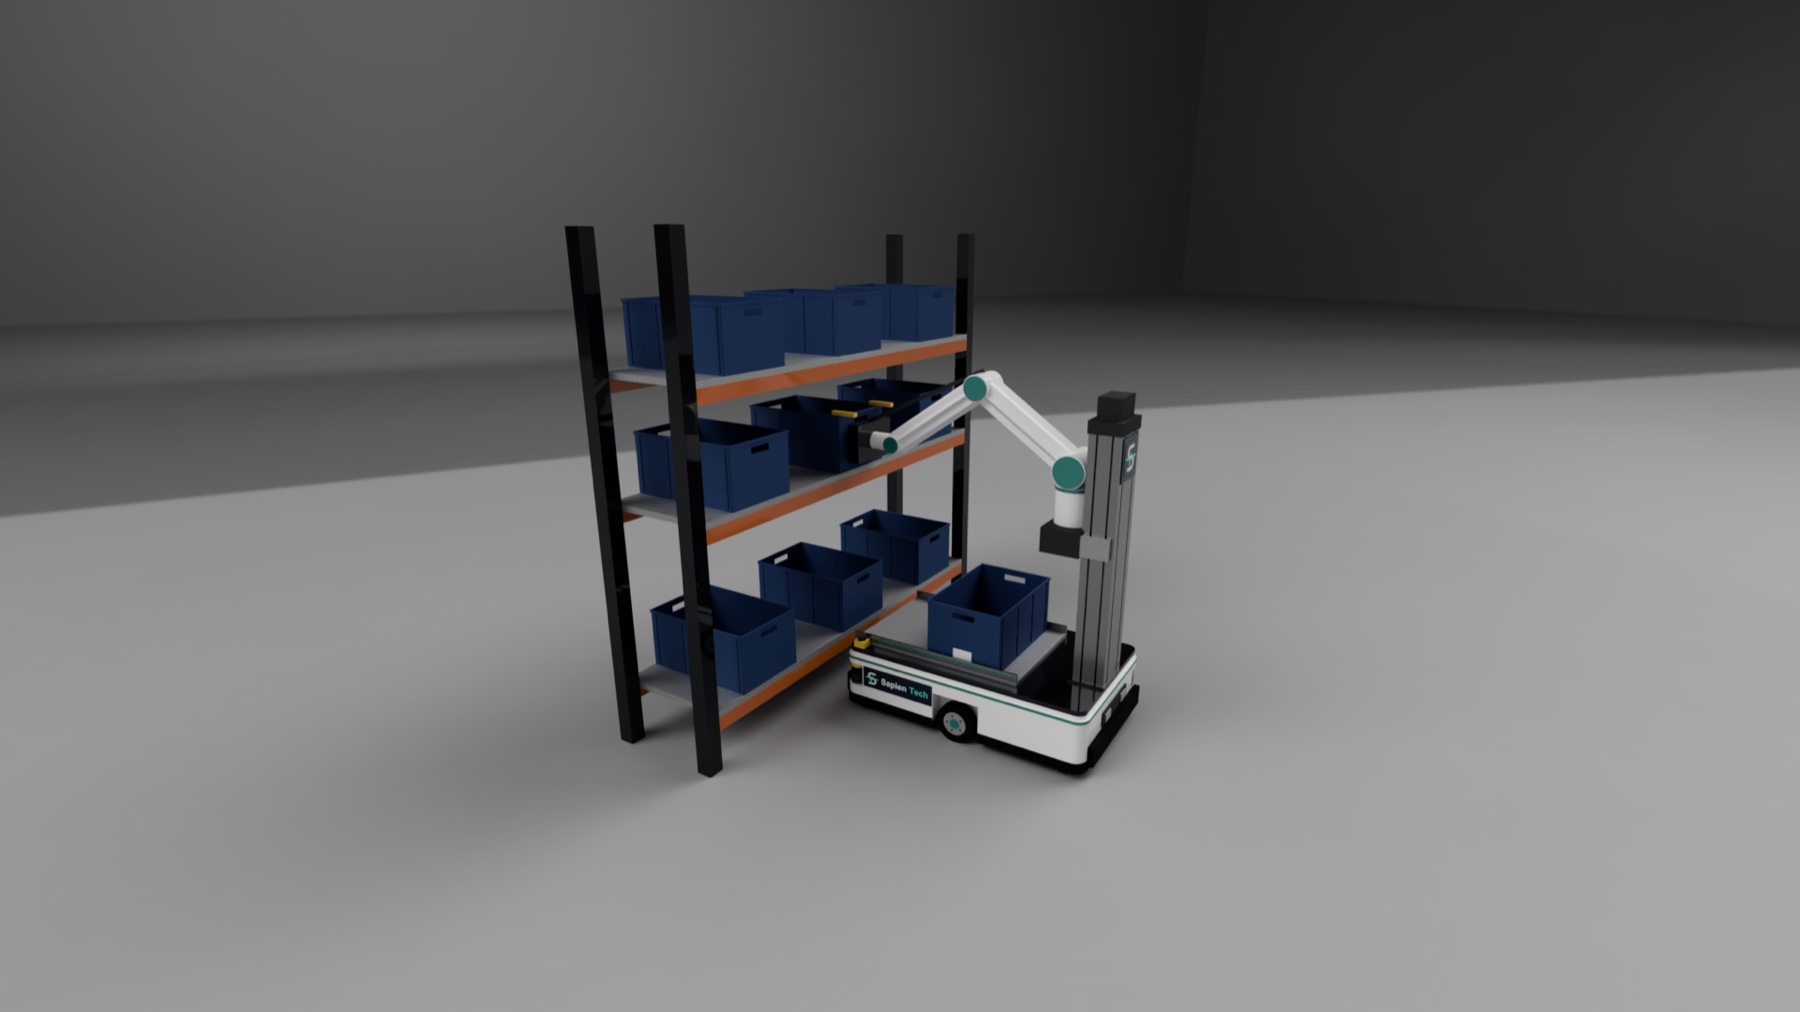
- Payload
- 15 kg tote
- Pick height
- 0.3–1.8 m
- Design rate
- 75 picks/h per robot
Concept · 3D design Figures are design calculations from the Fusion model. No physical testing yet; ratings are published only after testing.
Tell us about your items and orders.
Share item types, order lines per hour and where stock comes from.